Google patents telling robots how to walk using text commands
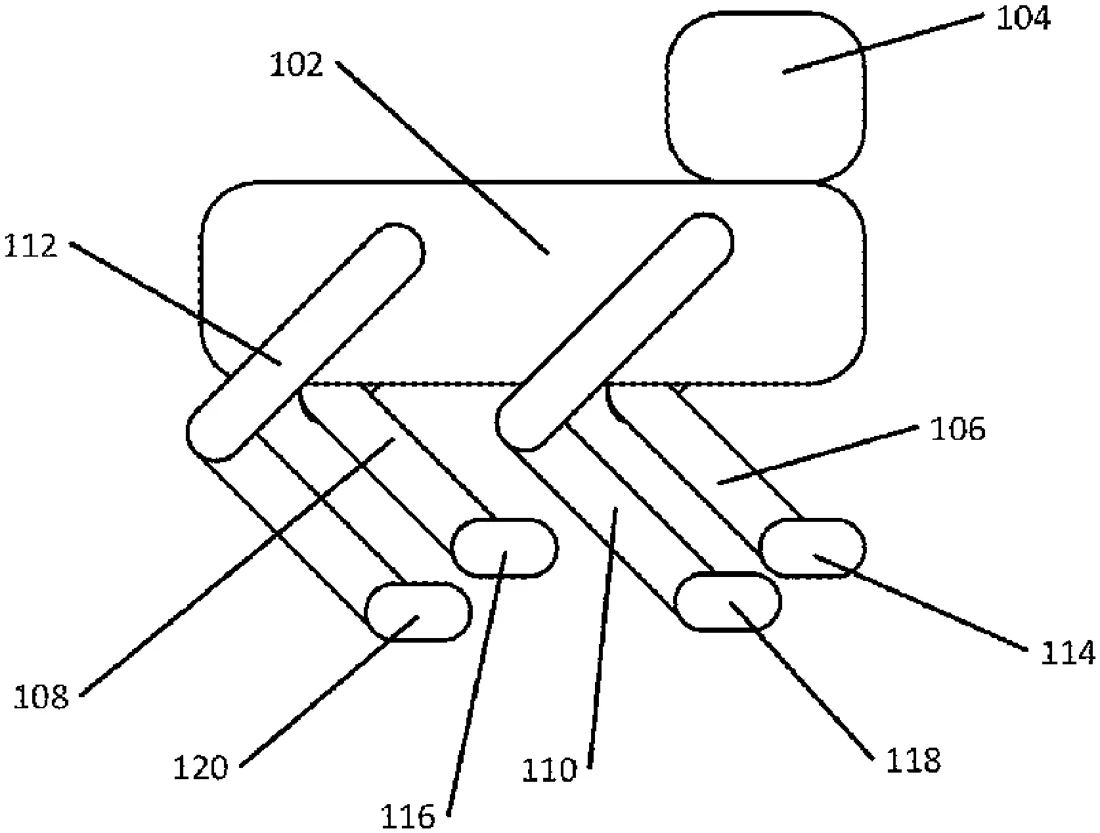
This patent describes a system where a robot receives a text description of a task and uses a large language model to figure out how to move. The model translates the text into a specific sequence of foot placements, which the robot then uses to walk or move across a surface.
In the filing’s own words
Various implementations are provided which include receiving an instance of natural language (NL) text input indicating a task for a multi-legged robot to perform in an environment. In many implementations, the system can process the NL text input using a large language model (LLM) to generate a foot contact pattern, indicating a sequence of leg positions of the robot relative to the surface, where one or more of the legs of the robot are in contact with the surface. Additionally or alternatively, the system can generate low-level robot control output by processing the foot contact pattern using a locomotion controller.
What exactly they claim (claim 1)
1. A method implemented by one or more processors, the method comprising: receiving an instance of natural language (NL) text input, wherein the instance of NL text input indicates a task for a robot to perform in an environment, wherein the robot has a plurality of legs, and wherein the robot is on a surface in the environment; processing the instance of NL text input using a large language model (LLM) to generate a foot contact pattern, wherein the foot contact pattern indicates a sequence of leg positions relative to the surface, of the plurality of legs of the robot, and wherein one or more of the legs of the robot are in contact with the surface; generating control output by processing the foot contact pattern using a locomotion controller of the robot; and causing the robot to perform one or more actions based on the control output.
Facts
- Company
- Google (GOOGLE LLC)
- Official title
- Foot contact pattern(s) as interface for language to control robot(s)
- Patent number
- US12801150B2
- Application number
- 19079035
- Filed
- Mar 13, 2025
- Granted
- Nov 17, 2026
- Inventors
- 5
- Claims
- 22
Classified under
G05D 1/43 Physics & computingG05D 1/2285 Physics & computingB62D 57/032 Operations & transportG05D 2101/10 Physics & computingG05D 2109/12 Physics & computingMore from Google in Robots & automation
- Google patents robot control via natural language instructions Oct 8, 2026
- Google patents robot control via AI-generated code Oct 15, 2026
- Google patents robot control via natural language instructions Oct 15, 2026
- Google patents robot that finds objects you point at using a stored map Sep 29, 2026
- Google patents robot vision that predicts how objects will move before acting Nov 10, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.