Google patents robot control via natural language instructions
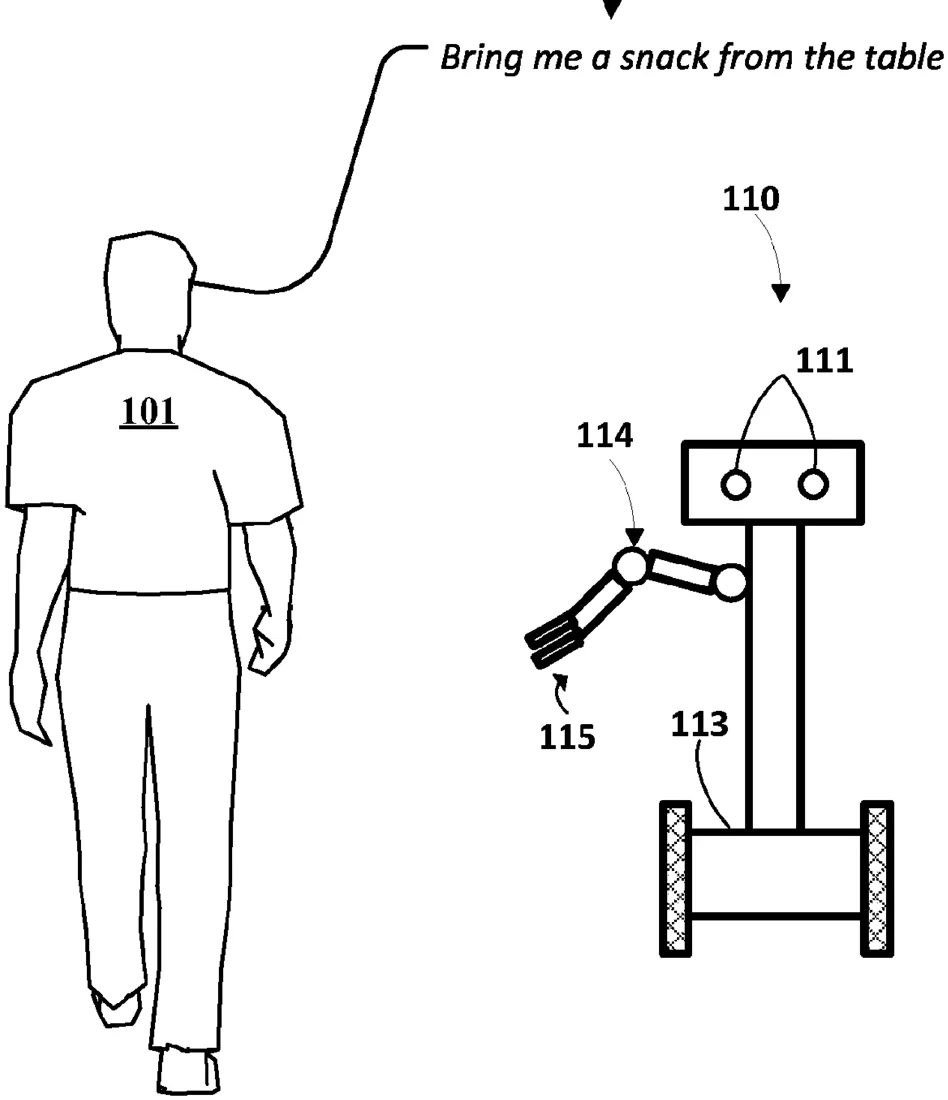
The filing describes a system where a robot receives free-form spoken or written commands and uses a large language model to break them down into specific physical actions. It combines this with real-time sensor data to check if the task is safe and possible before executing the movement.
In the filing’s own words
Implementations process, using a large language model, a free-form natural language (NL) instruction to generate to generate LLM output. Those implementations generate, based on the LLM output and a NL skill description of a robotic skill, a task-grounding measure that reflects a probability of the skill description in the probability distribution of the LLM output. Those implementations further generate, based on the robotic skill and current environmental state data, a world-grounding measure that reflects a probability of the robotic skill being successful based on the current environmental state data. Those implementations further determine, based on both the task-grounding measure and the world-grounding measure, whether to implement the robotic skill.
What exactly they claim (claim 1)
1. A method implemented by one or more processors, the method comprising: identifying a high-level instruction, the high-level instruction being a free-form natural language instruction; identifying state data that is based on sensor data captured by one or more sensor components of a robot; generating a prompt that includes the high-level instruction and the state data; processing the prompt using a sequence-to-sequence model to generate a sequence of steps that are in natural language and that describe a sequence of low-level skills that can be executed by the robot to accomplish the high-level instruction; in response to generating the sequence of steps: processing, using a policy model, (i) the natural language for a first low-level skill, of the sequence of low-level skills, and (ii) the sensor data or additional sensor data captured by one or more of the sensor components of the robot, to generate action output; and controlling the robot based on the action output generated based on the processing using the policy model.
Facts
- Company
- Google (GOOGLE LLC)
- Official title
- NATURAL LANGUAGE CONTROL OF A ROBOT
- Publication number
- US20260316289A1
- Application number
- 19700942
- Filed
- Jun 8, 2026
- Published
- Oct 15, 2026
- Inventors
- 6
- Claims
- 20
Classified under
B25J 13/003 Operations & transportB25J 9/161 Operations & transportB25J 9/163 Operations & transportB25J 11/0005 Operations & transportG06F 40/40 Physics & computingMore from Google in Robots & automation
- Google patents robot control via natural language instructions Oct 8, 2026
- Google patents robot control via AI-generated code Oct 15, 2026
- Google patents robot that finds objects you point at using a stored map Sep 29, 2026
- Google patents robot navigation check to prevent driving into known safe zones Sep 22, 2026
- Google patents robot brain that plans moves from camera views Oct 20, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.