Waymo patents self-driving car plan that always has a safe stop ready
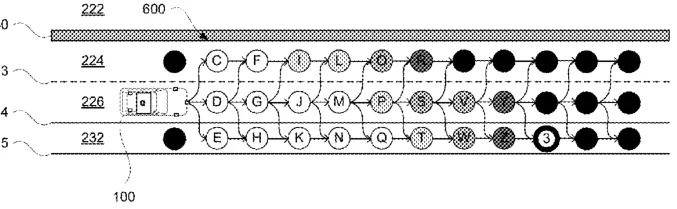
This patent describes a method for self-driving cars to plan their route while simultaneously calculating the cost of stopping at various nearby locations. The system creates a main path to the destination and a backup path to a safe stop, blending them into a single driving plan. If the car does not receive a new plan in time, it automatically follows the backup path to stop safely.
In the filing’s own words
Aspects of the disclosure provide for controlling an autonomous vehicle. For example, a set of potential stopping locations may be identified based on a current location of an autonomous vehicle. A set of potential states may be identified for the autonomous vehicle. A fallback cost for each potential state of the set of potential states to reach each potential stopping location of the set of potential stopping locations may be determined. A trajectory for an autonomous vehicle may be planned based on a route to a destination and the determined fallback costs. The autonomous vehicle may be controlled according to at least a portion of the trajectory.
What exactly they claim (claim 1)
1. A method for controlling an autonomous vehicle, the method comprising: identifying, by one or more processors, a set of potential stopping locations based on a current location of the autonomous vehicle; identifying, by the one or more processors, a set of potential states for the autonomous vehicle; determining, by the one or more processors, at least one gradient, wherein each gradient is associated with a corresponding potential stopping location of the set of potential stopping locations, and wherein each gradient represents fallback costs associated with reaching the corresponding potential stopping location of the set of potential stopping locations from each potential state of the set of potential states; planning, by the one or more processors, a nominal trajectory and at least one fallback trajectory for the autonomous vehicle based on a route to a destination and the determined fallback costs, wherein the nominal trajectory controls the autonomous vehicle towards the destination, and wherein the at least one fallback trajectory leads to a stopping location of the set of potential stopping locations; generating, by the one or more processors, a final trajectory including a portion of the nominal trajectory and a portion of the at least one fallback trajectory; controlling, by the one or more processors, the autonomous vehicle according to at least a portion of the final trajectory; and in response to not receiving an updated final trajectory prior to reaching the portion of the at least one fallback trajectory controlling, by the one or more processors, the autonomous vehicle according the at least one fallback trajectory to stop at the stopping location.
Facts
- Company
- Google (Waymo LLC)
- Official title
- Planning trajectories for controlling autonomous vehicles
- Patent number
- US12798606B2
- Application number
- 17862658
- Filed
- Jul 12, 2022
- Granted
- Nov 17, 2026
- Inventors
- 7
- Claims
- 22
Classified under
B60W 60/001 Operations & transportG01C 21/3453 Physics & computingB60W 2520/06 Operations & transportB60W 2520/10 Operations & transportB60W 2520/105 Operations & transportMore from Google in Cars & transport
- Waymo patents system to detect cyclists losing control before they fall Sep 8, 2026
- Waymo patents self-driving cars that hear sirens and pull over Sep 8, 2026
- Waymo patents AI that moves self-driving cars out of traffic jams Sep 29, 2026
- Waymo patents driverless cars with just two buttons for passengers Nov 3, 2026
- Waymo patents AI that predicts driving scenes from sensor data Oct 1, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.