Nvidia patents camera method to help robots find their exact location
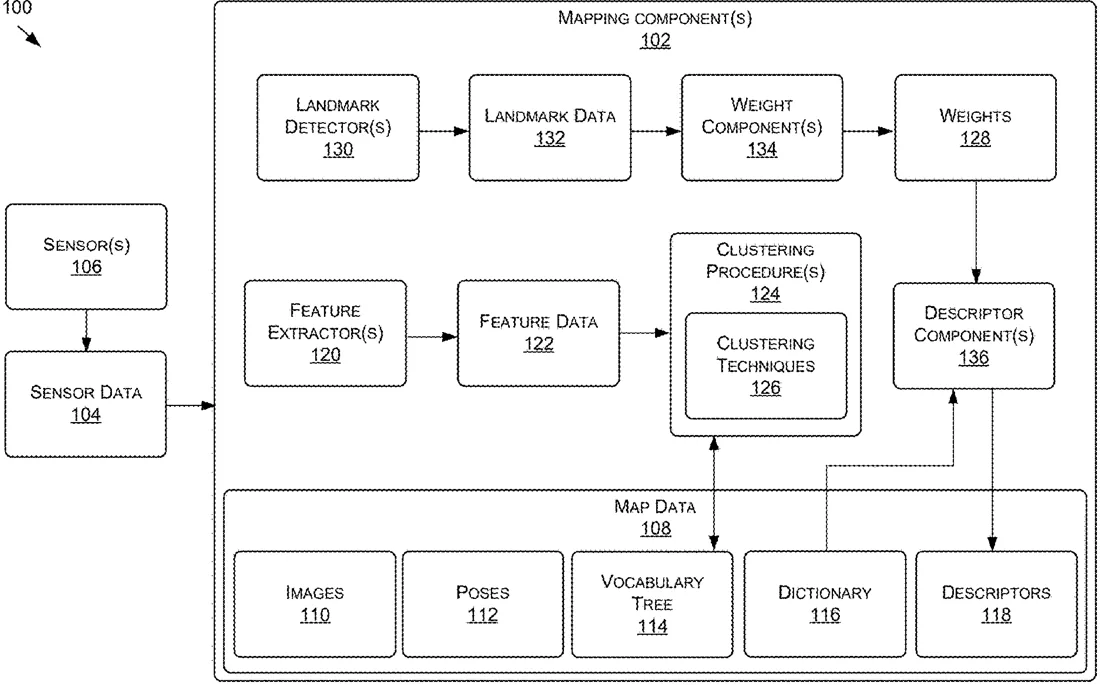
Nvidia describes a method that uses two camera images to figure out where a machine is in a pre-mapped environment. The system compares these images to a stored map to calculate the machine's precise position and orientation. It then refines this estimate using mathematical adjustments to ensure accuracy before the machine acts on that location data.
In the filing’s own words
In various examples, stereo image localization for autonomous and/or semi-autonomous systems and applications is described herein. Systems and methods may perform localization using two images from a stereo camera along with a map image from a localization map. For instance, a respective relative pose between each of the images and the map image may be determined along with a relative pose between the images. The relative poses may then be used to determine a predicted pose—such as an estimated rotation and/or an estimated translation—between one of the images and the map image. Additionally, the predicted pose may be refined using one or more optimization techniques, such as by minimizing distances between feature points of the images and epipolar lines associated with the points. The refined pose between the images may then be used to determine a localized pose of the machine within the environment.
What exactly they claim (claim 1)
1. A method comprising: receiving image data representing at least a left image obtained using a first sensor of a right image obtained using a second sensor of a machine; determining that at least one of the left image or the right image is related to a map image associated with a localization map of an environment; determining at least a first relative pose between the left image and the map image and a second relative pose between the right image and the map image; determining, based at least on the first relative pose and the second relative pose, a localized pose associated with the machine within the environment; and causing the machine to perform one or more operations based at least on the localized pose.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- IMAGE PAIR LOCALIZATION FOR AUTONOMOUS AND SEMI-AUTONOMOUS SYSTEMS AND APPLICATIONS
- Publication number
- US20260320822A1
- Application number
- 19174798
- Filed
- Apr 9, 2025
- Published
- Oct 15, 2026
- Inventors
- 5
- Claims
- 20
Classified under
G06T 7/74 Physics & computingG06T 7/85 Physics & computingG06T 2207/10012 Physics & computingG06T 2207/30244 Physics & computingG06T 2207/30252 Physics & computingMore from Nvidia in Robots & automation
- Nvidia patents robot control using language models to predict 3D positions Sep 10, 2026
- Nvidia patents method to teach humanoid robots to use hands via simulation Oct 15, 2026
- Nvidia patents 3D scene mapping that lets robots understand objects by name Oct 15, 2026
- Nvidia patents robot system that learns tasks from visual data Sep 29, 2026
- Nvidia patents method for robots to estimate object positions from images Oct 13, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.