Nvidia patents method for robots to estimate object positions from images
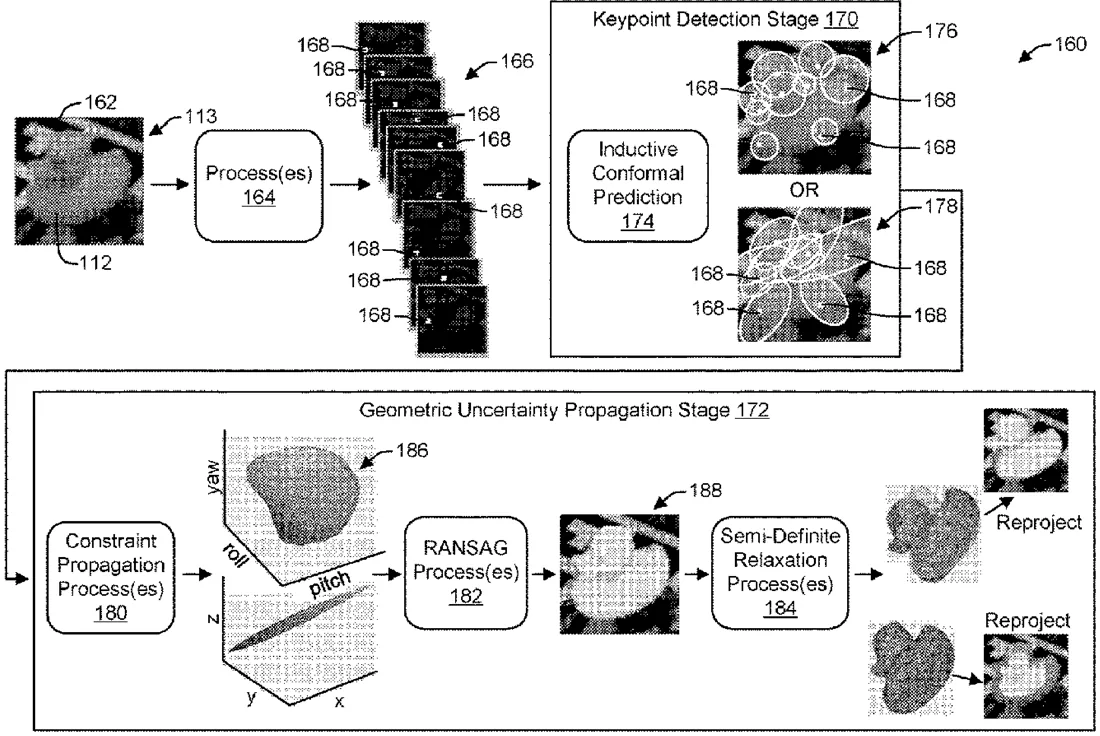
Nvidia has been granted a patent for a technique that helps autonomous machines figure out where objects are in space. The system uses machine learning to predict likely locations for specific points on an object, then calculates a final position to guide movement.
In the filing’s own words
Apparatuses, systems, and techniques to obtain prediction set(s) (e.g., region(s)) for keypoint prediction(s) based at least in part on data associated with an object, compute a set of candidate poses for the object based at least in part on the prediction set(s), and estimate an estimated object pose based at least in part on the set of candidate poses. The estimated object pose may be used to move a device. For example the estimated object pose may be used to provide collision-free motion generation for a real-world or virtual device (e.g., a robot, an autonomous machine, or a semi-autonomous machine). In at least one embodiment, at least a portion of the object pose estimation and/or at least a portion of the collision-free motion generation is performed in parallel.
What exactly they claim (claim 1)
1. An autonomous machine to: receive an estimated object pose; and move based at least in part on the estimated object pose, wherein the estimated object pose is created by at least one computing system by: obtaining a plurality of regions comprising different boundaries for a plurality of keypoints predicted by at least one machine learning process based at least in part on an image depicting an object, individual ones of the plurality of regions to have at least a predetermined probability of including a ground truth keypoint corresponding to a different one of the plurality of keypoints, generating a set of values representing points within the plurality of regions, and generating the estimated object pose based at least in part on the set of values.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- Object pose estimation
- Patent number
- US12759577B2
- Application number
- 18244050
- Filed
- Sep 8, 2023
- Granted
- Oct 13, 2026
- Inventors
- 2
- Claims
- 39
Classified under
B60W 60/001 Operations & transportB60W 50/0097 Operations & transportG06T 7/73 Physics & computingB60W 2420/403 Operations & transportG06T 2200/24 Physics & computingG06T 2207/20081 Physics & computingMore from Nvidia in Robots & automation
- Nvidia patents robot control using language models to predict 3D positions Sep 10, 2026
- Nvidia patents method to teach humanoid robots to use hands via simulation Oct 15, 2026
- Nvidia patents 3D scene mapping that lets robots understand objects by name Oct 15, 2026
- Nvidia patents robot system that learns tasks from visual data Sep 29, 2026
- Nvidia patents method to create new robot training videos from existing footage Sep 10, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.