Nvidia patents map-making method for robot path planning
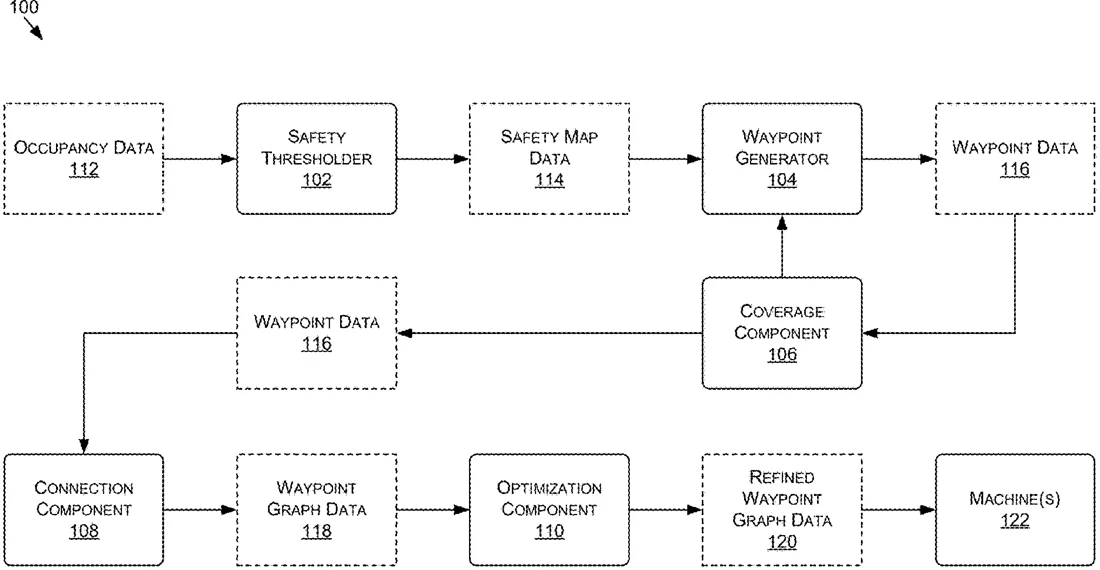
Nvidia describes a method for creating efficient navigation maps for autonomous machines by analyzing 2D images of an environment. The system places waypoints along obstacle boundaries and in open spaces, then connects them using geometric models to form a reliable path network.
In the filing’s own words
In various examples, sparse waypoint graphs may be generated using occupancy information to allow for efficient and reliable path planning for autonomous or semi-autonomous machines. For instance, the systems and methods of the present disclosure may analyze occupancy maps as 2D images to generate skeletons of free-space and obstacle contours, and strategically place nodes of the waypoint graph along these features. Additional nodes may then be iteratively added to under-represented, free-space regions based on distance metrics. For example, distance maps may be computed to indicate how far each point in the free-space is from the nearest existing node or obstacle, and new nodes may be placed at the most distant points (e.g., “local maxima”) if their distance exceeds a defined threshold. Edges of the waypoint graph may then be defined by connecting the nodes using geometric graph generation models—such as Delaunay triangulation.
What exactly they claim (claim 1)
1. A method comprising: obtaining image data representing an image of an occupancy map associated with an environment, the occupancy map indicating at least one or more occupied areas and one or more unoccupied areas in the environment; positioning one or more first nodes of a waypoint graph at one or more first locations in the image, the one or more first locations corresponding to one or more perimeters associated with the one or more occupied areas; positioning, based at least on the one or more first locations of the one or more first nodes, one or more second nodes of the waypoint graph at one or more second locations in the image corresponding to the one or more unoccupied areas; and generating, using one or more geometric graph generation models, one or more edges between nodes of the waypoint graph, the nodes including at least the one or more first nodes and the one or more second nodes.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- GENERATION OF WAYPOINT GRAPHS FOR ROBOTICS SYSTEMS AND APPLICATIONS
- Publication number
- US20260318688A1
- Application number
- 19178571
- Filed
- Apr 14, 2025
- Published
- Oct 15, 2026
- Inventors
- 1
- Claims
- 20
Classified under
G01C 21/20 Physics & computingG06T 7/73 Physics & computingG06T 2207/20072 Physics & computingMore from Nvidia in Robots & automation
- Nvidia patents robot control using language models to predict 3D positions Sep 10, 2026
- Nvidia patents method to teach humanoid robots to use hands via simulation Oct 15, 2026
- Nvidia patents 3D scene mapping that lets robots understand objects by name Oct 15, 2026
- Nvidia patents robot system that learns tasks from visual data Sep 29, 2026
- Nvidia patents method for robots to estimate object positions from images Oct 13, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.