Nvidia patents map-based method to train self-driving car vision
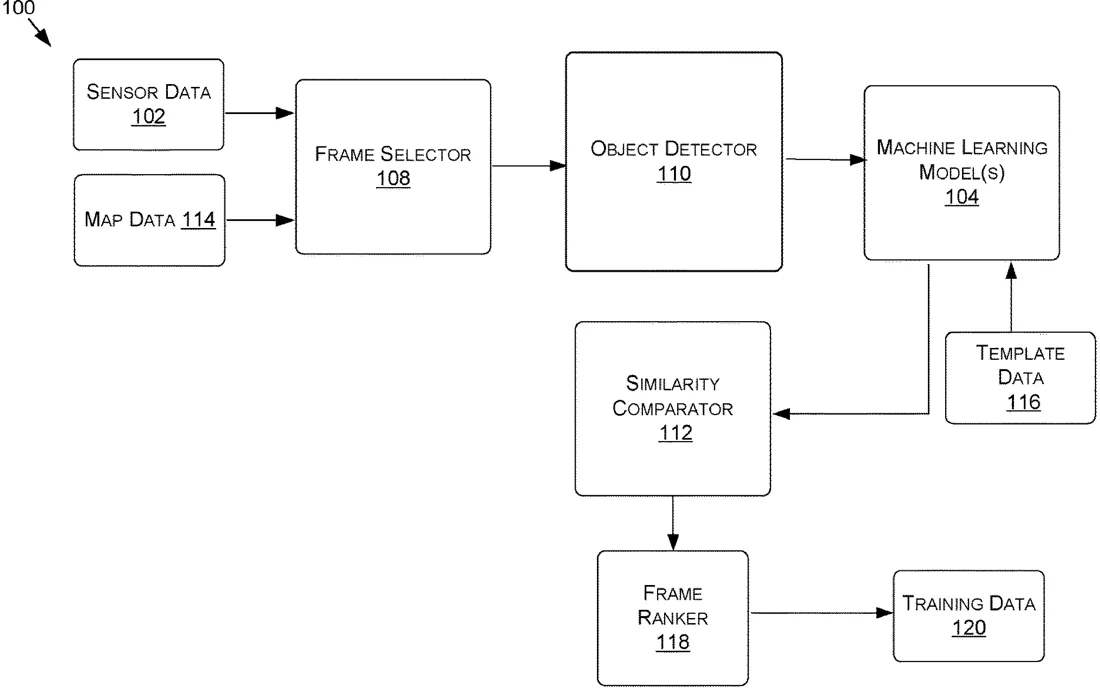
This filing describes a way to improve how autonomous vehicles recognize objects by using map data to find specific areas where those objects are likely to appear. It filters sensor data from these locations to build a focused training set for machine learning models, which helps the vehicle's perception system identify targets more accurately.
In the filing’s own words
In various examples, map data or geospatial data is used to identify a subset of sensor data having a higher likelihood of including representations of a target object of interest from a larger set of sensor data. Feature vectors corresponding to the subset of sensor data may then be compared to template feature vectors corresponding to the target object in order to confirm the depiction of the target object in the sensor data. The identified sensor data may be used to train one or more machine learning model to compute outputs that correspond to object identification. The trained machine learning models may be used to identify objects in order to aid an autonomous or semi-autonomous machine navigating within a surrounding environment.
What exactly they claim (claim 1)
1. A method comprising: causing a first machine to perform one or more planning or control operations within an environment based at least on detecting, using a perception model, a target object type in the environment, the perception model trained using a training dataset that includes one or more sensor data frames depicting one or more instances of the target object type, the training dataset generated, at least, by: determining, based at least on map data, one or more candidate geographic regions associated with the target object type; analyzing sensor data obtained using one or more sensors of one or more second machines operating in or within a threshold distance of the one or more candidate geographic regions; identifying, based at least on the analyzing, a portion of the sensor data in which an object corresponding to the target object type is depicted; and selecting, from the portion of the sensor data, the one or more sensor data frames to include in the training dataset.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- MACHINE NAVIGATION
- Publication number
- US20260316785A1
- Application number
- 19720621
- Filed
- Jun 25, 2026
- Published
- Oct 15, 2026
- Inventors
- 5
- Claims
- 20
Classified under
B60W 60/001 Operations & transportG01C 21/3807 Physics & computingG06N 20/00 Physics & computingB60W 2420/403 Operations & transportB60W 2420/408 Operations & transportB60W 2552/45 Operations & transportMore from Nvidia in Cars & transport
- Nvidia patents robotaxi system with AI dispatcher and virtual rails Sep 15, 2026
- Nvidia patents car drowsiness check that uses your body clock Oct 13, 2026
- Nvidia patents 3D camera system to measure passengers in vehicles Oct 13, 2026
- Nvidia patents cruise control that predicts driver's next move Oct 20, 2026
- Nvidia patents dual-brain system for self-driving cars Sep 17, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.