Nvidia patents method to check how accurately self-driving vehicles know their location
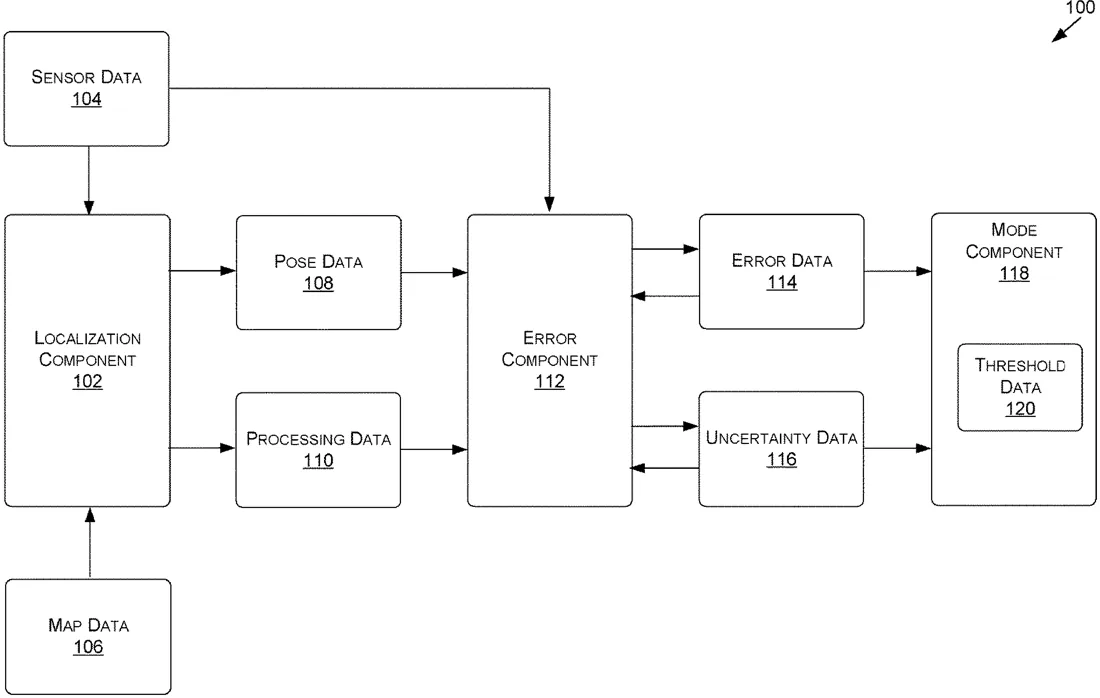
Nvidia describes a system that helps autonomous vehicles figure out exactly where they are by comparing two different ways of calculating position. One part uses a map and sensors to guess the location, while another part checks that guess against the vehicle's actual movement and visual details in the environment. The system then creates an accuracy score to tell the car how much it can trust its current position.
In the filing’s own words
In various examples, accuracy determinations for localization in autonomous and semi-autonomous systems and applications are described herein. Systems and methods are disclosed that determine one or more errors associated with vehicle localization using various types of sensor data generated using a vehicle. For instance, a first component of the vehicle may use a map and first sensor data to determine an estimated pose of the vehicle. A second component of the vehicle may then determine the error(s) associated with the estimated pose based on both actual motion of the vehicle within the environment, as determined using second sensor data, and comparing features represented by the first sensor data to features represented by the map. In some examples, the second component may further determine information associated with the error(s), such as one or more uncertainties associated with the error(s).
What exactly they claim (claim 1)
1. A method comprising: determining, based at least one or more differences between a motion pose and a localization pose associated with a machine within an environment, a pose error associated with the localization pose; determining, based at least on one or more differences between one or more first features represented by sensor data obtained using the machine and one or more second features represented by map data, a feature error associated with the localization pose; determining an accuracy metric associated with the localization pose based at least on the pose error and the feature error; and causing, based at least on the accuracy metric, the machine to navigate within the environment.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- MACHINE LOCALIZATION
- Publication number
- US20260316784A1
- Application number
- 19719055
- Filed
- Jun 24, 2026
- Published
- Oct 15, 2026
- Inventors
- 3
- Claims
- 20
Classified under
B60W 60/001 Operations & transportG01C 21/3867 Physics & computingB60W 2520/14 Operations & transportMore from Nvidia in Cars & transport
- Nvidia patents robotaxi system with AI dispatcher and virtual rails Sep 15, 2026
- Nvidia patents car drowsiness check that uses your body clock Oct 13, 2026
- Nvidia patents 3D camera system to measure passengers in vehicles Oct 13, 2026
- Nvidia patents cruise control that predicts driver's next move Oct 20, 2026
- Nvidia patents dual-brain system for self-driving cars Sep 17, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.