Nvidia patents method for cars to trace road lines from sensor data
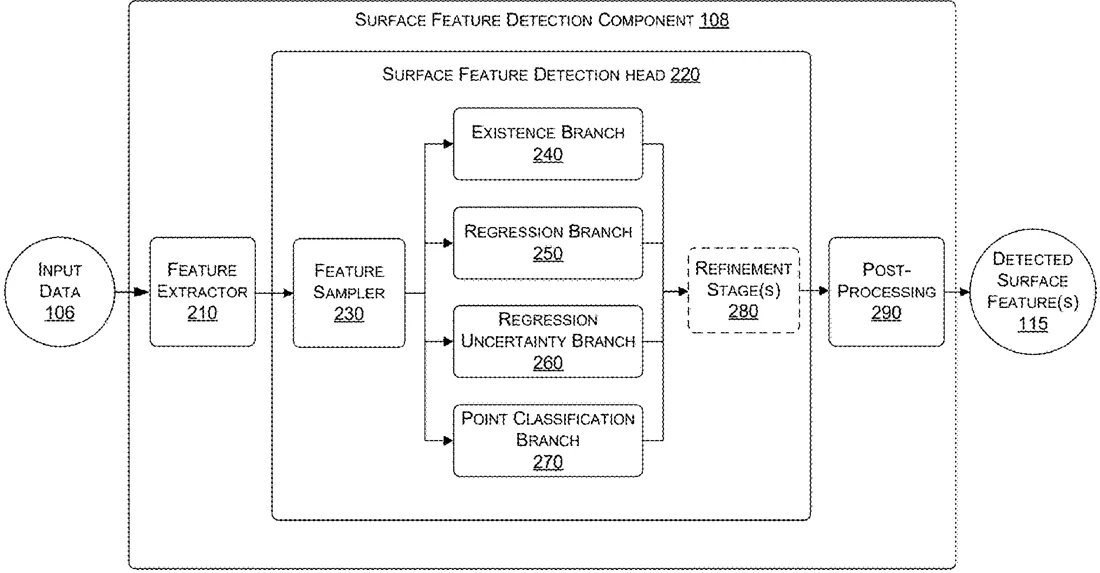
Nvidia describes a system that uses neural networks to detect surface features like lane lines or road boundaries from sensor data. It creates 2D or 3D lines representing these features by sampling specific points along predefined paths, helping autonomous vehicles understand their surroundings.
In the filing’s own words
In various examples, surface features such as lane lines or road boundaries may be detected and 2D or 3D polylines representing their shape may be regressed. For example, a set of predefined vertical, slanted, and/or curved anchors may be used to represent corresponding lines (e.g., in a top-down view or bird's eye view). For each anchor, extracted features may be sampled along the anchor and processed using one or more DNNs to generate global (e.g., anchor-level) predictions such as an anchor-level existence or confidence score and/or local (e.g., per-point) predictions for each of a set of sampled points along the anchor such as regressed polylines and per-point classifications. The detected surface features may be used by one or more control components such as a drive or control stack for localization, safe planning, and control of an autonomous vehicle, semi-autonomous vehicle, machine, robot, and/or other object or machine type.
What exactly they claim (claim 1)
1. One or more processors comprising processing circuitry to: determine, from sensor data generated using at least one sensor of an ego-machine in an environment, first data representing the environment; generate, using one or more Neural Networks (NNs) and based at least on the first data, a set of extracted features; generate, for at least one individual anchor of one or more linear or curved anchors, a set of sampled features based at least on sampling from the set of extracted features at locations associated with the at least one individual anchor; generate, using the one or more NNs and based at least on the set of sampled features for the at least one individual anchor of the one or more linear or curved anchors, second data representing at least one regressed line corresponding to at least one detected surface feature; and cause performance of one or more planning, control, or navigation operations associated with the ego-machine based on the second data.
Facts
- Company
- Nvidia (NVIDIA CORPORATION)
- Official title
- SURFACE FEATURE DETECTION FROM POINT CLOUDS FOR AUTONOMOUS AND SEMI-AUTONOMOUS SYSTEMS AND APPLICATIONS
- Publication number
- US20260311472A1
- Application number
- 19203467
- Filed
- May 9, 2025
- Published
- Oct 8, 2026
- Inventors
- 3
- Claims
- 20
Classified under
G06V 10/82 Physics & computingG06V 10/754 Physics & computingG06V 10/764 Physics & computingMore from Nvidia in Cars & transport
- Nvidia patents robotaxi system with AI dispatcher and virtual rails Sep 15, 2026
- Nvidia patents car drowsiness check that uses your body clock Oct 13, 2026
- Nvidia patents 3D camera system to measure passengers in vehicles Oct 13, 2026
- Nvidia patents cruise control that predicts driver's next move Oct 20, 2026
- Nvidia patents dual-brain system for self-driving cars Sep 17, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.