Nvidia patents robot simulation method that cuts down on contact calculations
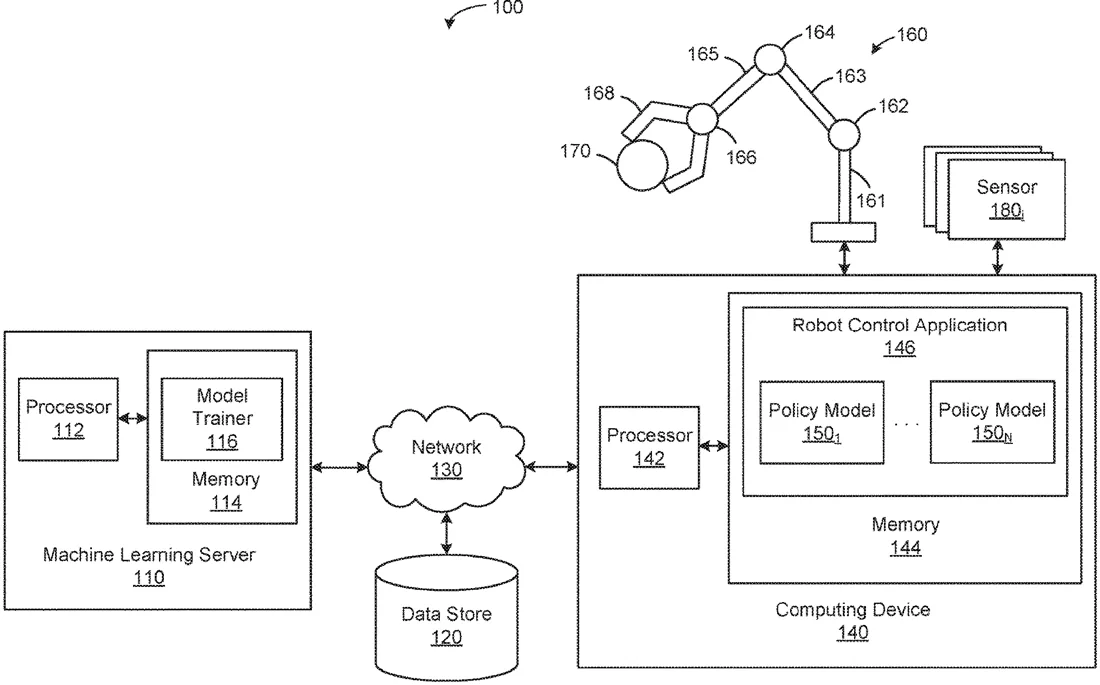
Nvidia describes a way to speed up computer simulations of robots by ignoring unnecessary physical interactions. The system identifies which parts of objects are actually touching and removes redundant data points before running the simulation. This allows a machine learning model to be trained more efficiently on how the robot should move.
In the filing’s own words
One embodiment of a method for controlling a robot includes performing a plurality of simulations of a robot interacting with one or more objects represented by one or more signed distance functions (SDFs), where performing the plurality of simulations comprises reducing a number of contacts between the one or more objects that are being simulated, and updating one or more parameters of a machine learning model based on the plurality of simulations to generate a trained machine learning model.
What exactly they claim (claim 1)
1. A computer-implemented method for robot simulation, the method comprising: reducing a set of contacts between a plurality of objects based at least on spatial proximity between contacts included in the set of contacts and normals associated with the contacts to generate a reduced set of contacts; and performing, based at least on the reduced set of contacts, one or more operations to simulate a robot interaction involving the plurality of objects.
Facts
- Company
- Nvidia (NVIDIA CORPORATION)
- Official title
- SIMULATION AND REINFORCEMENT LEARNING TECHNIQUES FOR PERFORMING ROBOTIC TASKS
- Publication number
- US20260295823A1
- Application number
- 19702913
- Filed
- Jun 9, 2026
- Published
- Oct 1, 2026
- Inventors
- 12
- Claims
- 20
Classified under
B25J 9/163 Operations & transportB25J 9/161 Operations & transportB25J 9/1666 Operations & transportB25J 9/1671 Operations & transportMore from Nvidia in Robots & automation
- Nvidia patents robot control using language models to predict 3D positions Sep 10, 2026
- Nvidia patents method to teach humanoid robots to use hands via simulation Oct 15, 2026
- Nvidia patents 3D scene mapping that lets robots understand objects by name Oct 15, 2026
- Nvidia patents robot system that learns tasks from visual data Sep 29, 2026
- Nvidia patents method for robots to estimate object positions from images Oct 13, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.