Tesla patents method to train self-driving software using simulated driving
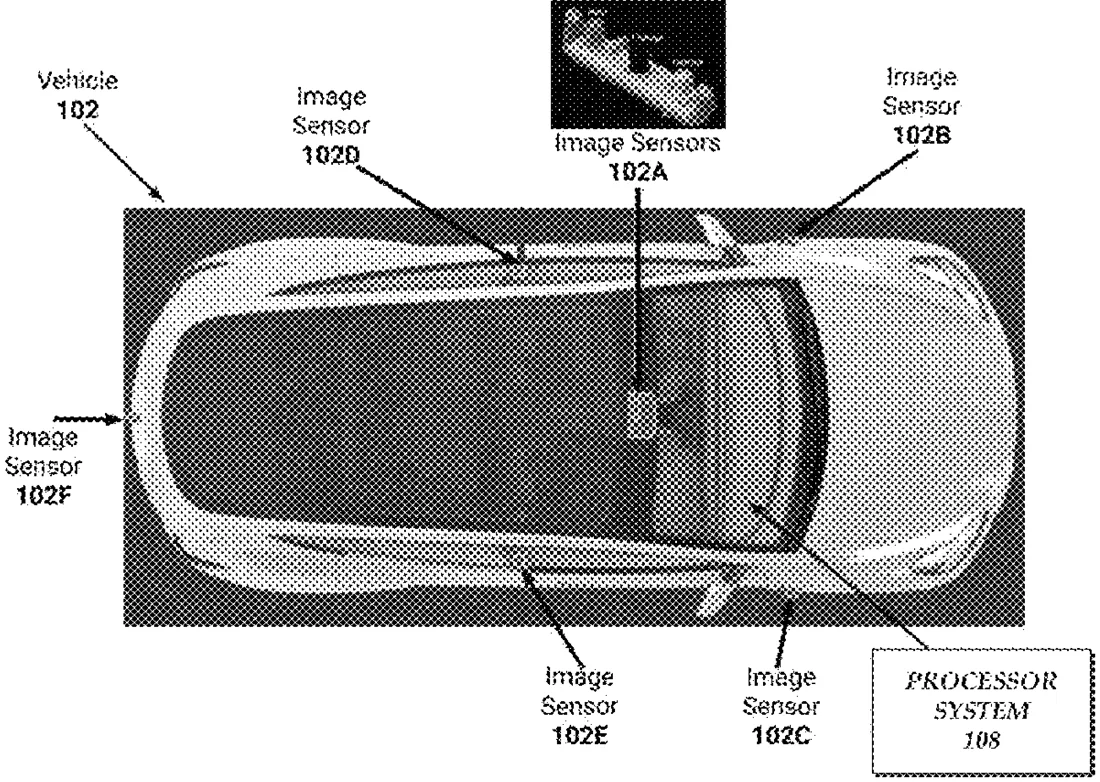
This patent describes a system that creates virtual driving environments from real camera footage captured by Tesla vehicles. It then simulates driving in these environments to test and improve the software that controls the car, using the results to generate better training data for the machine learning models.
In the filing’s own words
Systems and methods for training machine learning algorithms utilized for autonomous driving. An example method includes creating driving environments based at least on vision based image data received from a vehicle; simulating driving a virtual vehicle by importing driving environment scenario; in response to completing the simulation, analyzing simulated results; determining optimized driving parameters associated with the driving environment scenario; and generating a set of machine learning algorithms training data based on the determined optimized driving parameters. The driving environment scenario is based at least on the created driving environment.
What exactly they claim (claim 1)
1. A system comprising one or more processors and non-transitory computer storage medium storing instructions that when executed by the one or more processors, cause the processors to generate a set of machine learning algorithms training data, wherein the system is included in a simulation system, and wherein the generation of the training data comprises: creating driving environments based at least on vision-based image data received from one or more two-dimensional cameras of a vehicle; simulating driving a virtual vehicle by importing only vision-based image data associated with driving environment scenarios, wherein the driving environment scenario is based at least on the created driving environment, wherein, during the simulation, the system: monitors performance of the virtual vehicle, and dynamically updates at least one parameter of at least one vision-based machine learning model based on the performance, and wherein the system uses an updated at least one vision-based machine learning model for subsequent simulations; in response to completing the simulation, analyzing simulated results; determining optimized driving parameters associated with the driving environment scenario; and generating the set of machine learning algorithms training data based on the determined optimized driving parameters.
Facts
- Company
- Tesla (Tesla, Inc.)
- Official title
- Supplementing vision-based system training with simulated content
- Patent number
- US12755551B2
- Application number
- 18320888
- Filed
- May 19, 2023
- Granted
- Oct 6, 2026
- Inventors
- 4
- Claims
- 14
Classified under
G06V 20/56 Physics & computingG06T 5/70 Physics & computingG06T 17/00 Physics & computingG06V 10/70 Physics & computingMore from Tesla in AI & software
- Tesla patents method to share object labels between different car sensors Sep 17, 2026
- Tesla patents faster math for car navigation AI Oct 1, 2026
- Tesla patents faster math for self-driving AI Oct 1, 2026
- Tesla patents method to speed up AI calculations in self-driving cars Oct 1, 2026
- Tesla patents method to speed up AI processing in self-driving cars Oct 1, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.