Nvidia patents method for cars to blend camera and radar data
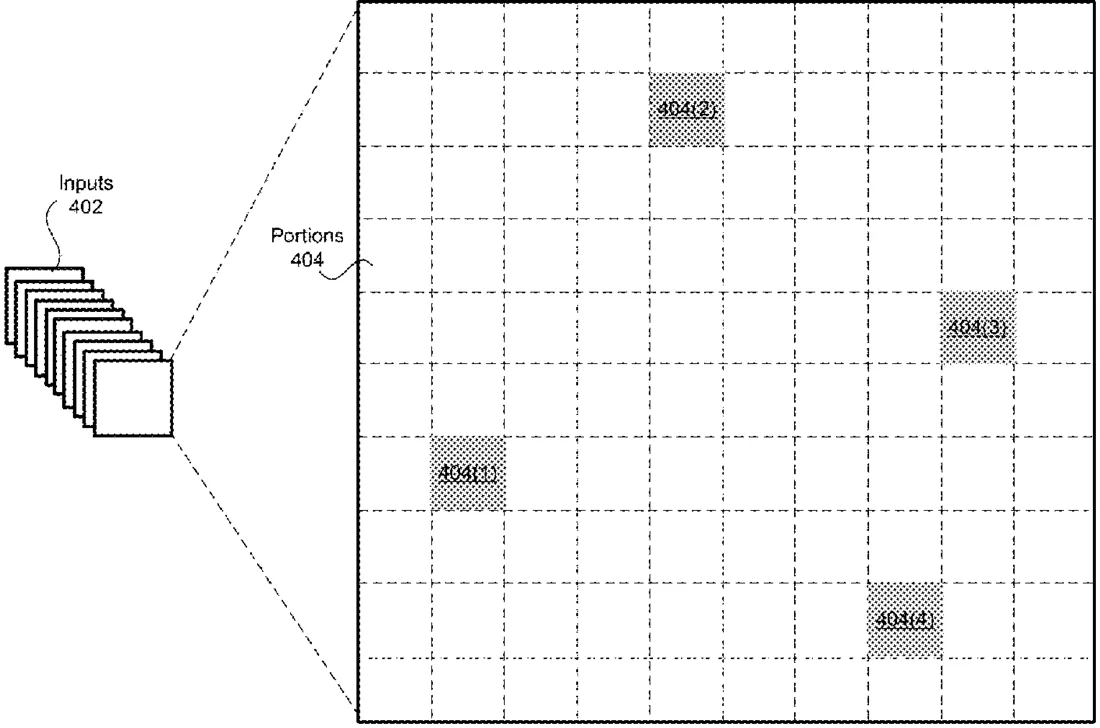
Nvidia describes a system that combines data from different car sensors, like cameras and radar, to get a clearer picture of nearby objects. It uses a computer program to merge this information, helping the vehicle understand where objects are and how they are moving.
In the filing’s own words
In various examples, sensor fusion for autonomous or semi-autonomous systems and applications is described. Systems and methods are disclosed that use data pipelines to process sensor data generated using different types of sensors (e.g., image sensors, RADAR sensors, LiDAR sensors, etc.) in order to generate first data representing information associated with objects surrounding a vehicle. For instance, the information may represent values for parameters associated with the objects, such as locations of the objects, dimensions of the objects, velocities of the objects, orientations of the objects, classifications of the objects, and/or any of parameters. The systems and methods may then process the first data using one or more machine learning models (e.g., one or more deep neural networks) that are trained to fuse the information (e.g., the parameters) and output second data representing final information associated with the objects. The fused output may then be used to perform downstream operations.
What exactly they claim (claim 1)
1. A method comprising: determining, based at least on first sensor data obtained using a first type of sensor, first values for parameters associated with an object located within an environment at a first instance in time; determining, based at least on second sensor data obtained using a second type of sensor, second values for the parameters associated with the object at a second instance in time; generating input data representative of at least: a plurality of first grids associated with the first type of sensor, the plurality of first grids indicating the first values for the parameters within first portions of the plurality of first grids that are associated with a location of the object within the environment; and a plurality of second grids associated with the second type of sensor, the plurality of second grids indicating the second values for the parameters within second portions of the plurality of second grids that are associated with the location of the object within the environment; determining, using one or more neural networks and based at least on the input data, third values for the parameters associated with the object; and causing a machine to navigate within the environment based at least on the third values for the parameters.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- Object detection using sensor fusion for autonomous systems and applications
- Patent number
- US12755521B2
- Application number
- 18314323
- Filed
- May 9, 2023
- Granted
- Oct 6, 2026
- Inventors
- 2
- Claims
- 20
Classified under
G06V 10/82 Physics & computingG06V 10/80 Physics & computingMore from Nvidia in Cars & transport
- Nvidia patents robotaxi system with AI dispatcher and virtual rails Sep 15, 2026
- Nvidia patents car drowsiness check that uses your body clock Oct 13, 2026
- Nvidia patents 3D camera system to measure passengers in vehicles Oct 13, 2026
- Nvidia patents cruise control that predicts driver's next move Oct 20, 2026
- Nvidia patents dual-brain system for self-driving cars Sep 17, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.