Nvidia patents method for self-driving cars to pick best route path
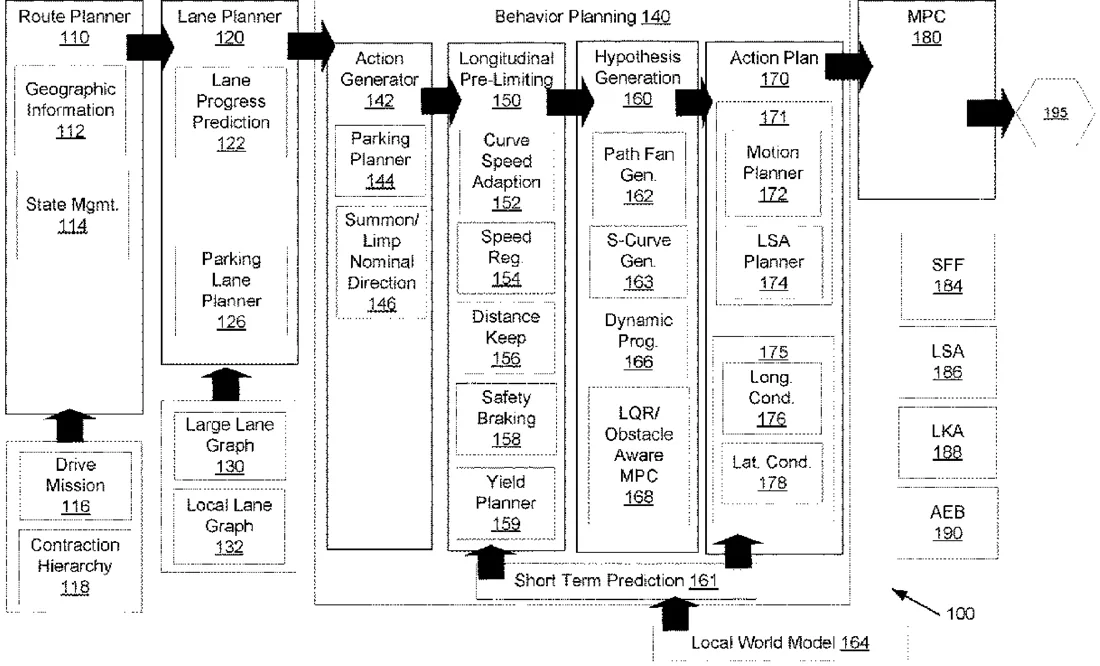
Nvidia has patented a system that helps autonomous vehicles choose the best path by scoring multiple possible routes. The system uses a graph of potential future locations to calculate costs like time and fuel, then combines these scores to select the most efficient trajectory for the car to follow.
In the filing’s own words
Embodiments of the present disclosure relate to behavior planning for autonomous vehicles. The technology described herein selects a preferred trajectory for an autonomous vehicle based on an evaluation of multiple hypothetical trajectories by different components within a planning system. The various components provide an optimization score for each trajectory according to the priorities of the component and scores from multiple components may form a final optimization score. This scoring system allows the competing priorities (e.g., comfort, minimal travel time, fuel economy) of different components to be considered together. In examples, the trajectory with the best combined score may be selected for implementation. As such, an iterative approach that evaluates various factors may be used to identify an optimal or preferred trajectory for an autonomous vehicle when navigating an environment.
What exactly they claim (claim 1)
1. A method comprising: selecting, for a machine, a planned route that includes a sequence of waypoints to a destination based at least on a location of the machine and a metric quantifying traversal of the planned route; based at least on the selecting, propagating, from a node that corresponds to a proxy destination in a graph of potential future locations for the machine, a location score that quantifies the traversal of the planned route in a direction toward the proxy destination, the propagating being through nodes of the graph and computing respective remaining costs for the machine to reach the proxy destination along the planned route in the direction searching the graph for a nominal path to reach the proxy destination along the planned route in the direction using the respective remaining costs to evaluate paths through the nodes; generating one or more trajectories that correspond to the nominal path; and performing one or more control operations corresponding to the machine based at least on the one or more trajectories.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- Behavior planning for autonomous vehicles
- Patent number
- US12752816B2
- Application number
- 18620096
- Filed
- Mar 28, 2024
- Granted
- Oct 6, 2026
- Inventors
- 16
- Claims
- 20
Classified under
B60W 60/0011 Operations & transportB60W 50/0097 Operations & transportG05D 1/0212 Physics & computingG05D 1/646 Physics & computingG06N 3/08 Physics & computingMore from Nvidia in Cars & transport
- Nvidia patents robotaxi system with AI dispatcher and virtual rails Sep 15, 2026
- Nvidia patents car drowsiness check that uses your body clock Oct 13, 2026
- Nvidia patents 3D camera system to measure passengers in vehicles Oct 13, 2026
- Nvidia patents cruise control that predicts driver's next move Oct 20, 2026
- Nvidia patents dual-brain system for self-driving cars Sep 17, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.