Nvidia patents method to check if multiple cameras are still aligned
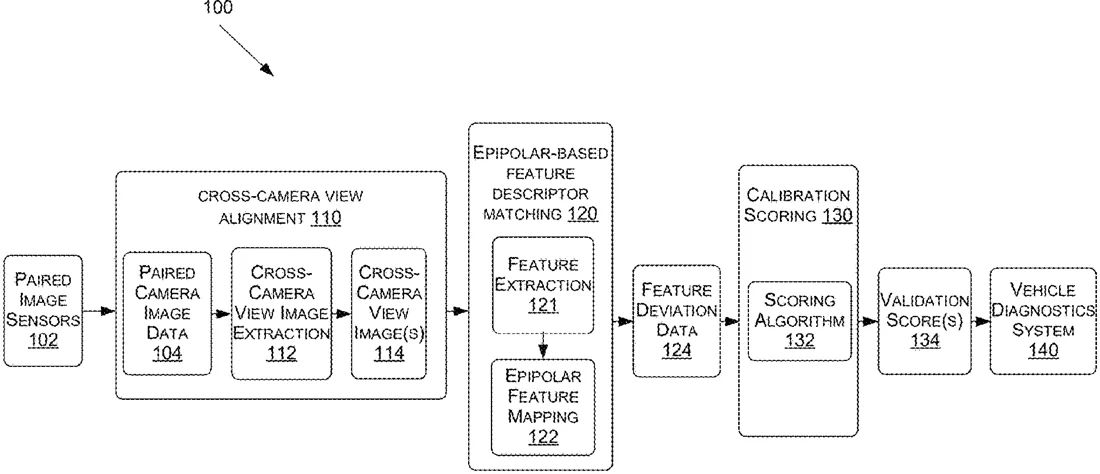
This patent describes a way to check if two cameras that see the same area are still properly aligned. It compares specific points in the images from both cameras to see if they match up according to the expected geometry, creating a score that shows if the calibration is still good.
In the filing’s own words
In various examples, epipolar constraint-based cross-camera calibration validation is disclosed. For a pair of cameras that have partially overlapping fields of view, a shared region of their overlapping fields of view may be extracted and used as the basis to perform an epipolar constraint-guided feature descriptor matching process. A camera calibration metric may be computed based on the degree to which a feature descriptor appearing at a pixel of the first image aligns as expected in the second image with an epipolar line associated with the pixel of the first image, where the epipolar line is computed using extrinsic camera calibration parameters associated with the pair of cameras. Epipolar matching may be performed for a plurality of feature points and an aggregate validation score computed based on measuring the computed deviations for each feature. A sensitivity analysis may be applied to better assess the usefulness of the validation score.
What exactly they claim (claim 1)
1. One or more processors comprising processing circuitry to: detect a shared region appearing in one or more pairs of image frames from at least one pair of cameras having at least partially overlapping fields of view; extract at least one pair of cross-camera view images comprising the shared region from the one or more pairs of image frames from at least one pair of cameras having at least partially overlapping fields of view; associate at least one feature point of a feature detected from a first view image of the at least one pair of cross-camera view images with at least one matching feature point from a second view image of the at least one pair of cross-camera view images; compute for the second view image at least one epipolar line based at least on a location of the at least one feature point within the first view image; determine a calibration validation score for the at least one pair of cameras based at least on a deviation between a location of the at least one matching feature point and the at least one epipolar line; and generate an indication of whether a current calibration between the at least one pair of cameras is valid for continued use based at least on a determination of whether the calibration validation score satisfies a validation criteria.
Facts
- Company
- Nvidia (NVIDIA Corporation)
- Official title
- Sensor calibration
- Patent number
- US12770295B2
- Application number
- 18609302
- Filed
- Mar 19, 2024
- Granted
- Oct 20, 2026
- Inventors
- 7
- Claims
- 20
Classified under
G06T 7/80 Physics & computingG06V 10/44 Physics & computingG06V 10/751 Physics & computingMore from Nvidia in Cameras & imaging
- Nvidia patents cameras that share data to track objects together Sep 10, 2026
- Nvidia patents eye-tracking to hide image stitching seams Sep 17, 2026
- Nvidia patents method to fix warped lines in wide-angle photos Oct 1, 2026
- Nvidia patents method to blend infrared and visible light images Oct 8, 2026
- Nvidia patents method to fix colors in high dynamic range images Oct 6, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.