Nvidia patents method to find object position using multiple sensor types
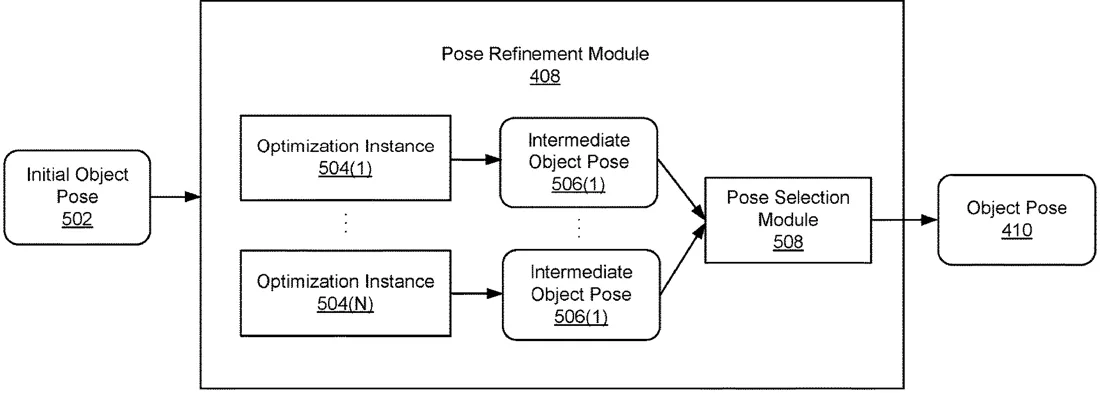
Nvidia describes a computer method that figures out where an object is in 3D space by comparing different types of sensor data, such as images and depth scans. The system uses a process called differentiable rendering, which allows the computer to adjust its guess of the object's position repeatedly until the simulated view matches the real sensor data.
In the filing’s own words
One embodiment of a method for determining object poses includes receiving first sensor data and second sensor data, where the first sensor data is associated with a first modality, and the second sensor data is associated with a second modality that is different from the first modality, and performing one or more iterative operations to determine a pose of an object based on one or more comparisons of (i) one or more renderings of a three-dimensional (3D) representation of the object in the first modality with the first sensor data, and (ii) one or more renderings of the 3D representation of the object in the second modality with the second sensor data.
What exactly they claim (claim 1)
1. A computer-implemented method for determining three-dimensional (3D) representations of objects, the method comprising: receiving acquired sensor data in a plurality of modalities; and performing one or more first iterative optimization operations to determine a first 3D representation of an object based at least on comparisons of a plurality of differentiable renderings of the object in the plurality of modalities with corresponding sensor data in the plurality of modalities from the acquired sensor data.
Facts
- Company
- Nvidia (NVIDIA CORPORATION)
- Official title
- TECHNIQUES FOR DIFFERENTIABLE DEEP OBJECT POSE ESTIMATION
- Publication number
- US20260311365A1
- Application number
- 19715929
- Filed
- Jun 22, 2026
- Published
- Oct 8, 2026
- Inventors
- 6
- Claims
- 20
Classified under
G06T 7/75 Physics & computingG06T 15/04 Physics & computingG06T 2207/10024 Physics & computingG06T 2207/10028 Physics & computingG06T 2207/20081 Physics & computingMore from Nvidia in AI & software
- Nvidia patents AI coach that analyzes your gameplay to suggest strategies Oct 13, 2026
- Nvidia patents AI system that writes and voices character conversations Sep 10, 2026
- Nvidia patents system that uses AI to find bugs in game videos Sep 17, 2026
- Nvidia patents AI method to make digital characters move realistically Sep 8, 2026
- Nvidia patents AI system that builds image generators from text prompts Sep 15, 2026
Summaries are simplified from the filing’s own abstract and first claim. A patent filing is not a product announcement.
Patent data and drawings: U.S. Patent and Trademark Office (USPTO). Nebula is not affiliated with or endorsed by the USPTO.